All board projects
Quality open-source board projects and technical materials from CrowdSupply, Hackaday, and Hackster.io, all in one place
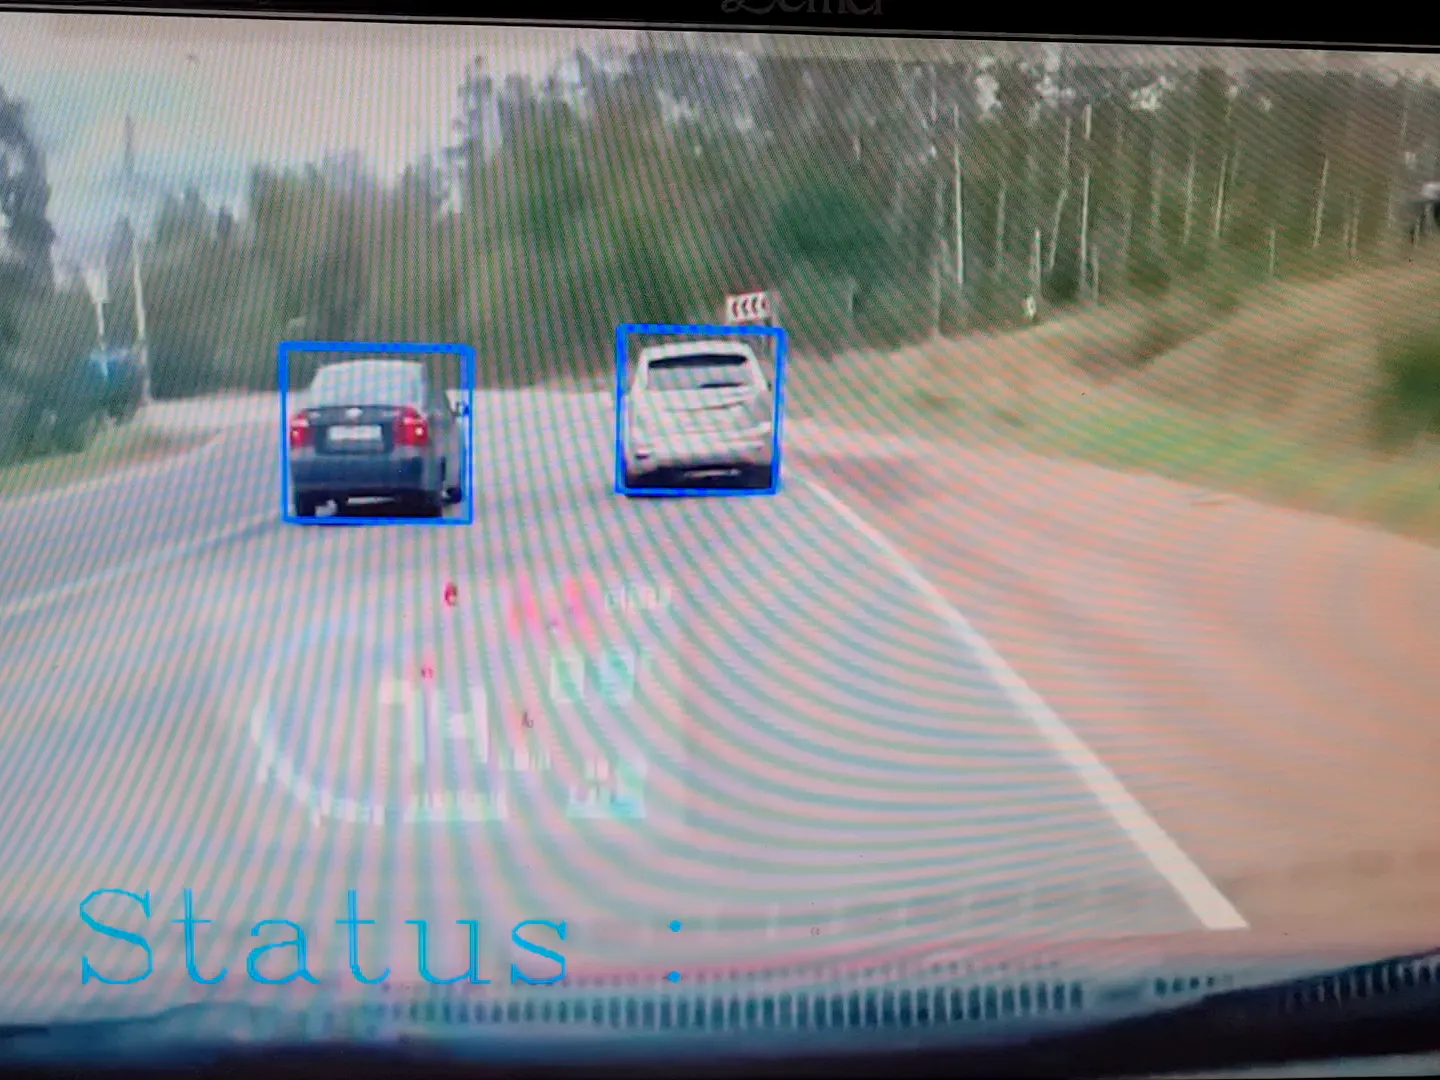
Accident Detection with KV260
This project use theKV260 starter kit to monitor traffic from CCTV and detect whether there are any accidents.
Custom Yocto Linux & Network Boot for Xilinx KR260
Build a fast, network-bootable Yocto Linux for KR260 with PYNQ, XRT, Jupyter, and FPGA/RPU support—your complete foundation for PL, RPU, etc
Space Hackathon: ARLISS Challenge
ARLISS Foliding Wing Aircraft with Vectored Thrust.
Getting Started with AMD Spartan™ 7 FPGA in Vitis™ 2023.2
This project walks through how to develop software applications to run on the MicroBlaze processor in an SP701 using Vitis Unified 2023.2.
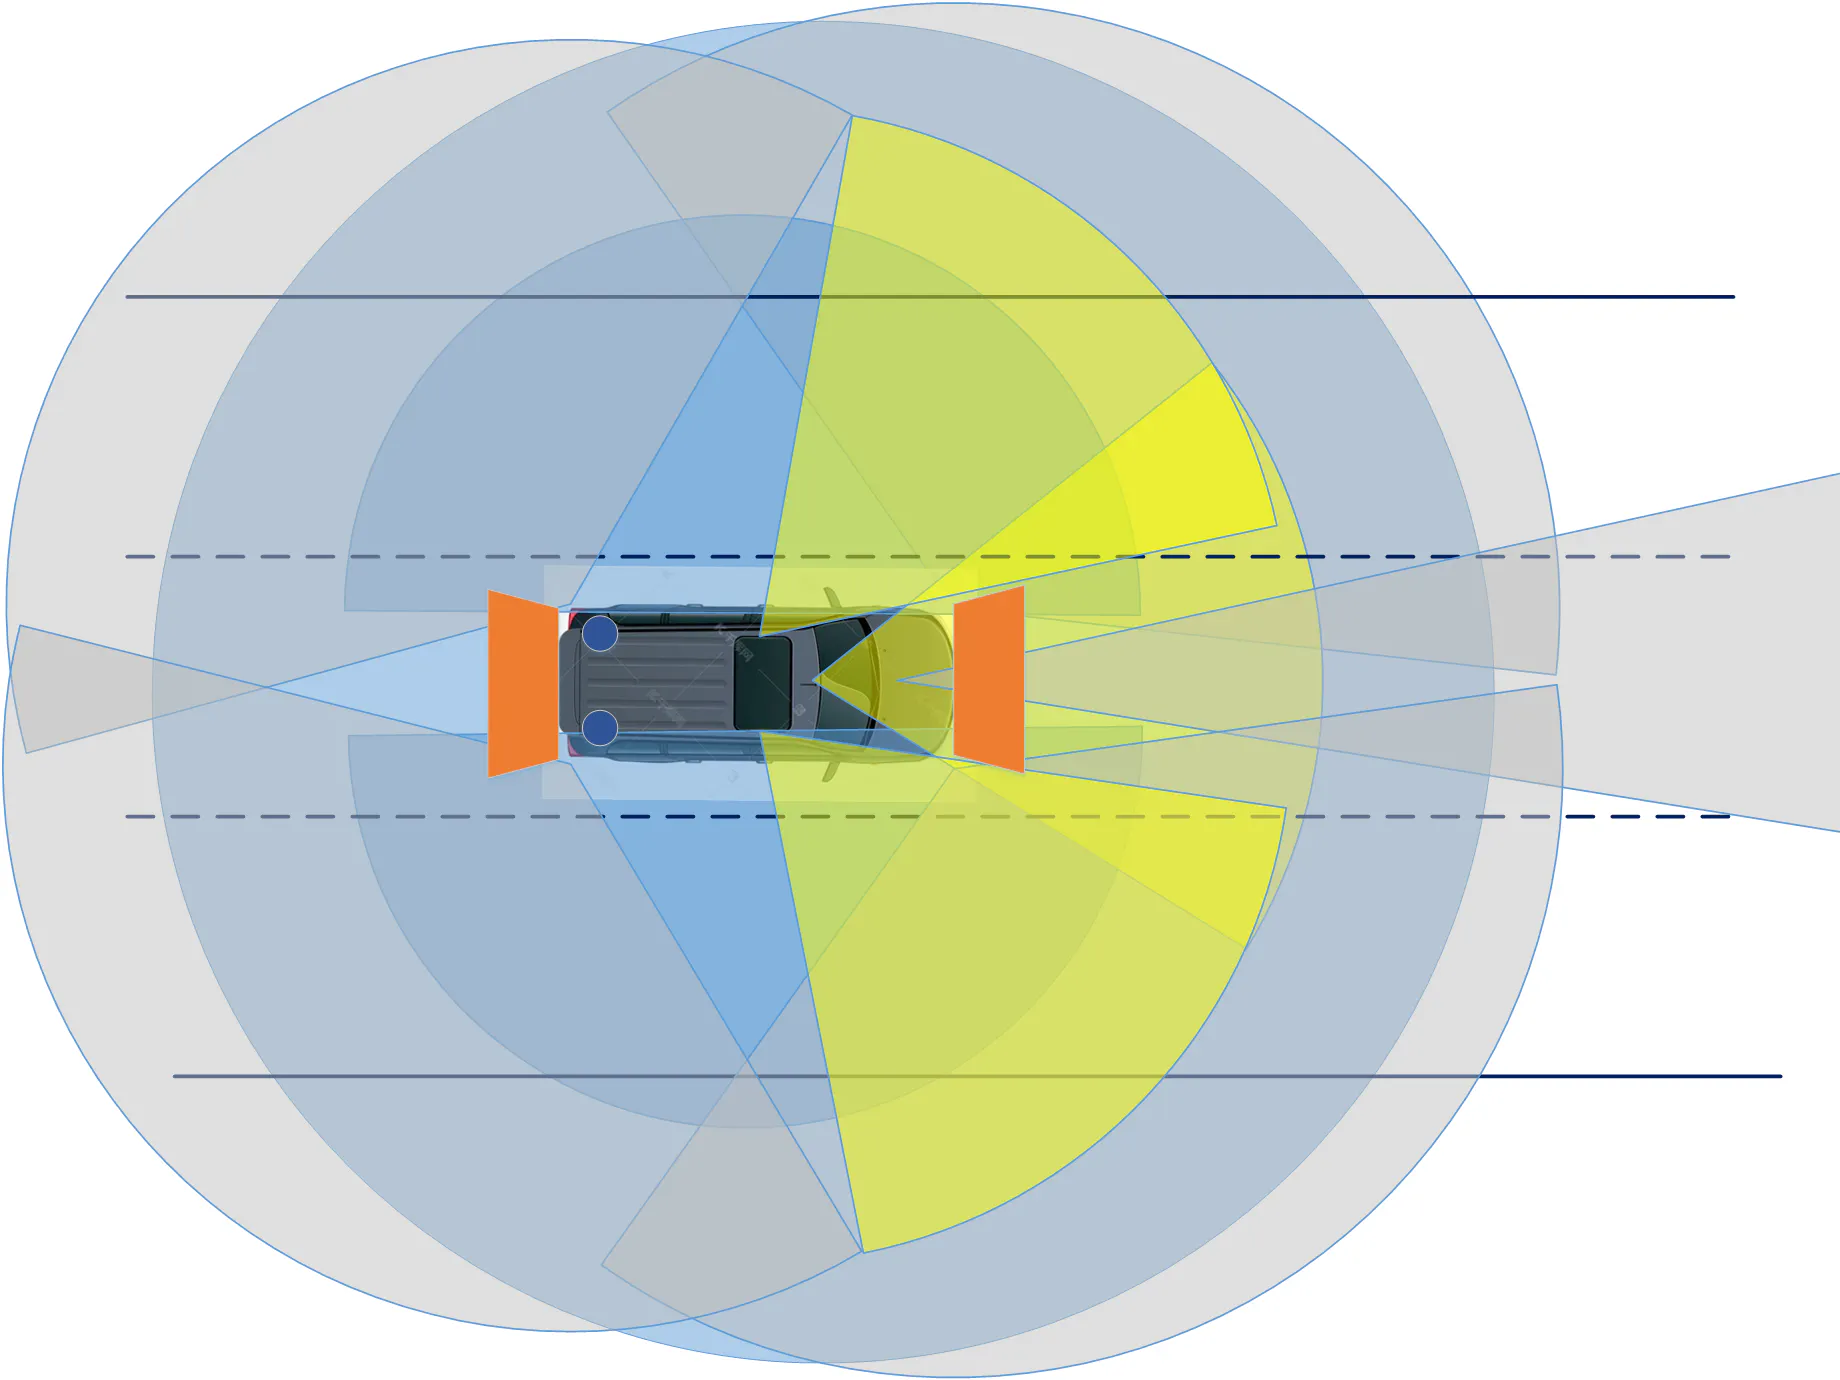
Multi-Sensor Localization for Autonomous Drving
Use lidar, gnss, imu, chassis to know vehicle ego-pose and state, which is needed in ADAS and more advanced Autonomous Driving.
Tria Vitis Platforms - Building the Foundational Designs
Tria provides pre-verified designs for its platforms. This project describes how to re-generate the Vivado 2023.2 designs from source.
J-Eye: Intramuscular Site Detection for Autonomous Injection
This project explores a low-cost solution for detecting intramuscular injection site to empower the next-gen autonomous vaccine injection.
LungAI : A Digital COVID-19 Detector
A Deep Learning based Web Application to Detect and Predict COVID-19
Tria Vitis Platforms - Adding support for Vitis-AI 3.5
This project describes how to add support for Vitis-AI 3.5 to the Tria Vitis Platforms.
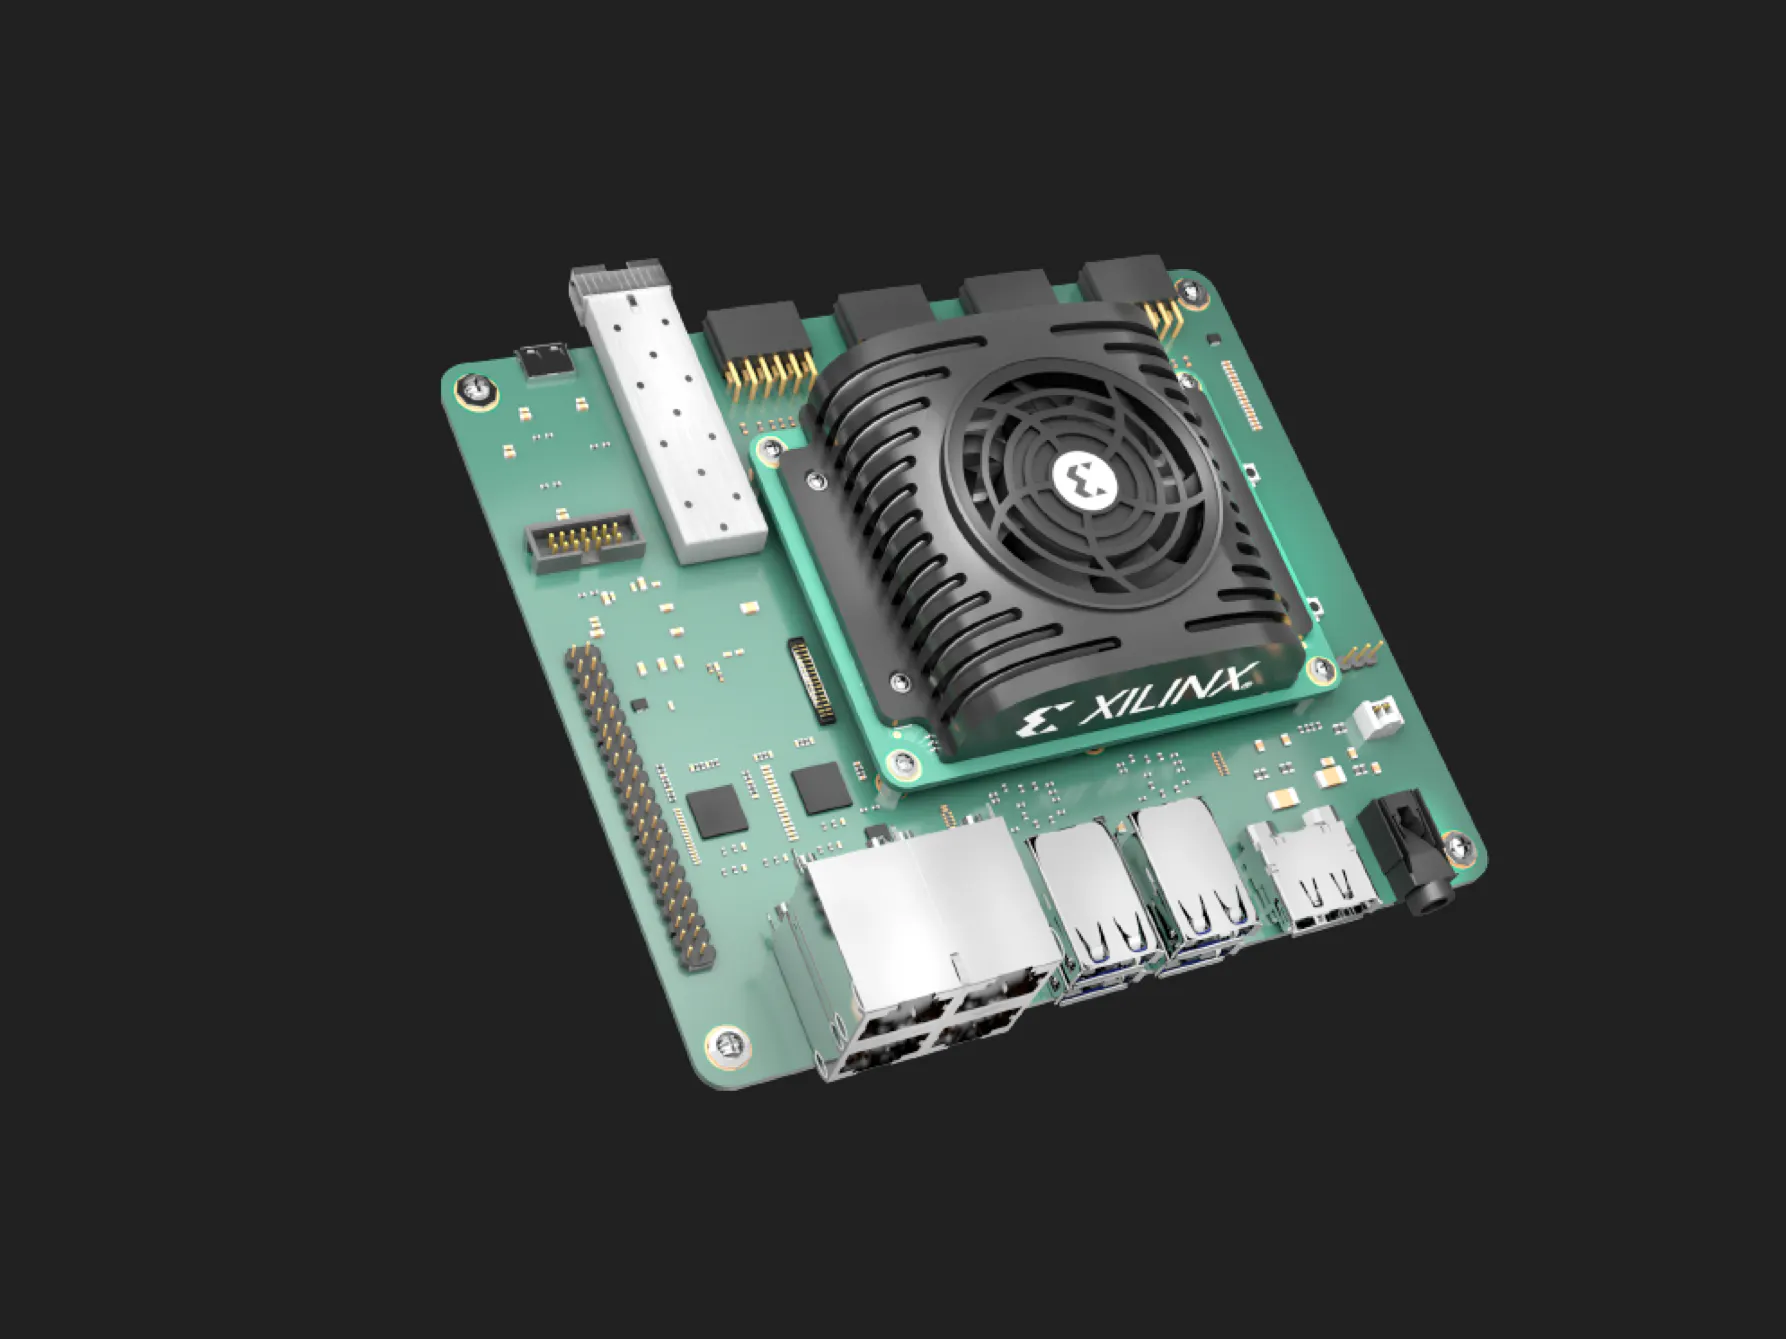
ROS 2 Humble in AMD KR260 with Yocto
Yocto and ROS 2 Humble allow you to build custom Linux-based production-grade operating systems for robots with AMD KR260.
Classifying Darth Vader & Yoda with AI & Intel AI DevCloud
Build and train a convolutional neural network that can identify Darth Vader & Yoda on the Intel AI Devcloud (Colfax)
Credits to authors and platforms
All projects aggregated here come from the open-source platforms listed above, and copyright remains with the original authors. We respect the work of every open-source contributor, and all content follows its original open-source license. If you are a project author and would like the related content removed, please contact us.