30 秒结论
「WheelBot -Robotic Drive and Steering Unit for AMRs」是 ZouIC 从 Hackster.io 收录的开源项目,机器人方向。面向科研级 AMR 的差速驱动与转向单元:采用平衡车电机、ODrive 驱动,并通过 CAN 总线连接 M5Stack Core S3。
- 来源平台
- Hackster.io
- 方向
- 机器人
- 许可证
- 以原页面标注为准
- 作者
- George Negret
- 发布时间
- 2026-07-19
常见问题
WheelBot -Robotic Drive and Steering Unit for AMRs 是做什么的?
面向科研级 AMR 的差速驱动与转向单元:采用平衡车电机、ODrive 驱动,并通过 CAN 总线连接 M5Stack Core S3。
WheelBot -Robotic Drive and Steering Unit for AMRs 的内容来源是哪里?
这条记录收录自 Hackster.io,原文地址 https://www.hackster.io/wheelbot/wheelbot-robotic-drive-and-steering-unit-for-amrs-c4fa26。
WheelBot -Robotic Drive and Steering Unit for AMRs 用了什么技术栈?
标签 Intel、tutorial、advanced。
WheelBot -Robotic Drive and Steering Unit for AMRs 是什么开源许可证?
ZouIC 收录这条记录时未标注具体许可证,条款以原始页面为准。
WheelBot -Robotic Drive and Steering Unit for AMRs 是谁做的?
来源页标注的作者为 George Negret。
WheelBot -Robotic Drive and Steering Unit for AMRs 是什么时候发布的?
来源页面标注的发布时间是 2026-07-19。
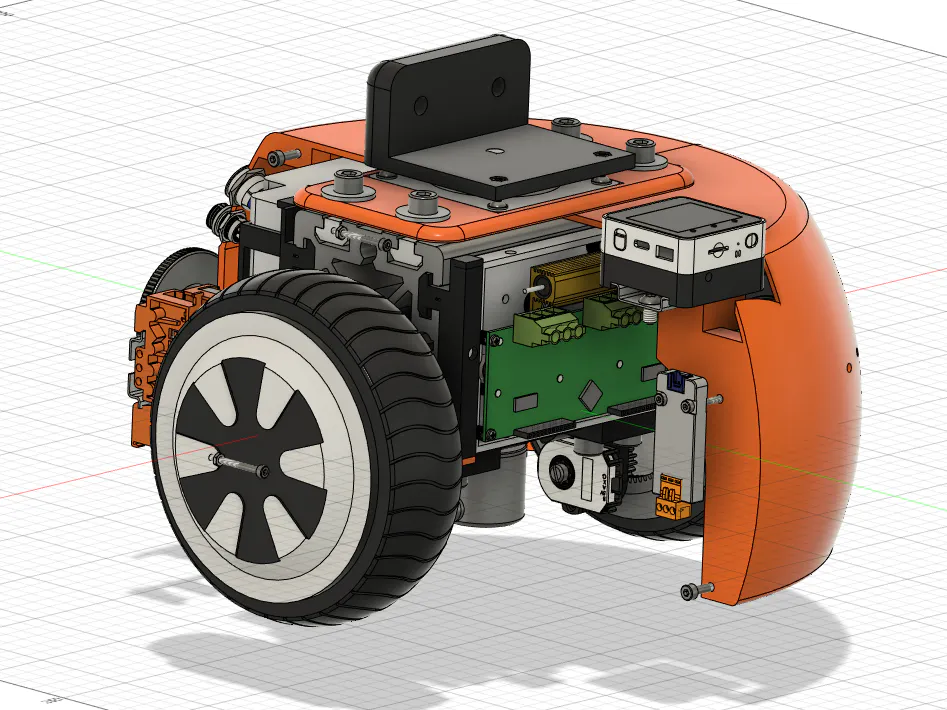
面向科研级 AMR 的差速驱动与转向单元:采用平衡车电机、ODrive 驱动,并通过 CAN 总线连接 M5Stack Core S3。
技术规格详情
source platform
Hackster.io
listing note
Metadata fetched from the public platform page; copyright belongs to the original author.
difficulty
advanced
content type
tutorial
相关资源与购买渠道
统计数据
respects
4
views
92